Kyiv Dynamics [ CONTACT US ]
-:--- mission.asmTop (1,0)Git-master (Odyssey)
> SCROLL TO RUN THE MISSION_
> GPS .............. NOT REQUIRED
> POSITION ......... ROAD MATCHED
> TERRAIN .......... ROAD SAND GRASS WATER
> DRIVER ........... NONE
> OPERATOR ......... 1 : WHOLE FLEET
Software first

> We don't build the vehicle. We make yours autonomous.

Odyssey is software. It runs on a small computer on board, takes the vehicle's own controls, and turns a remote-controlled machine into one that drives itself. Licensed per robot, so vehicle makers can build it in.
┤odyssey/├
../
easy_integration/plugs into the vehicle's own controls. Autonomous in a day
on_board/every decision made on the robot, no cloud
one_app/the whole fleet, any mix of vehicles
no_connection/keeps working when the link is jammed or lost: holds, carries on or comes home
How a robot thinks

> Four steps, many times a second, on the robot itself.

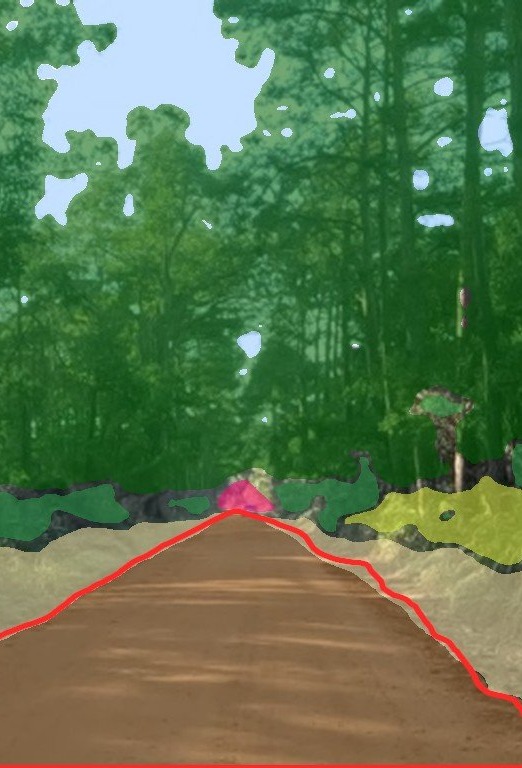
The camera view with the ground classified: road, sand, grass

Camera reads road, sand, grass, water.

SEE
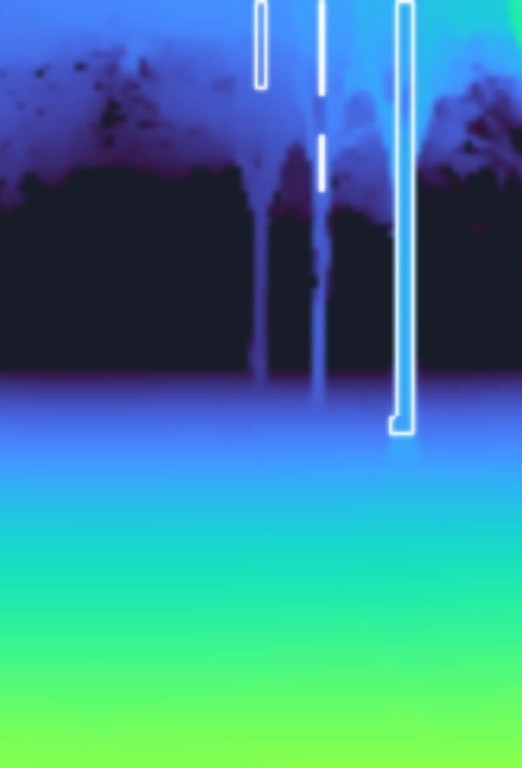
Depth: tree trunks outlined as obstacles

Depth places what stands up: trees, bushes, people.

LOCATE
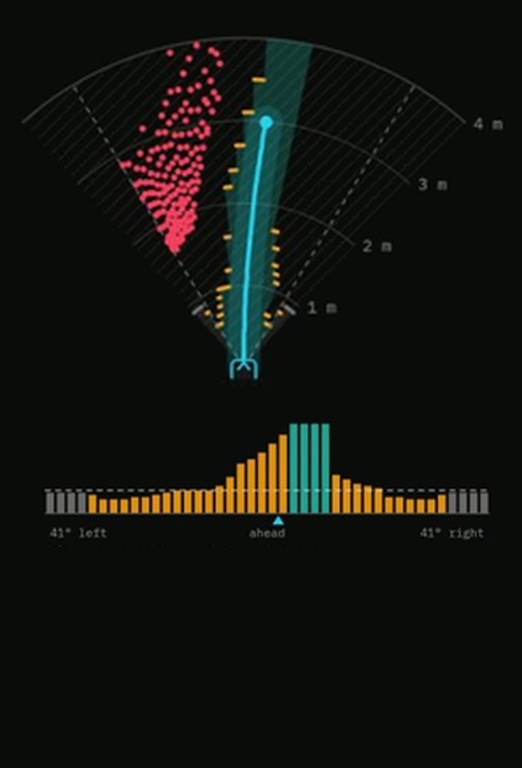
The rover's navigation view: obstacles and the way it chose

Cheapest safe way, obstacles avoided.

DECIDE
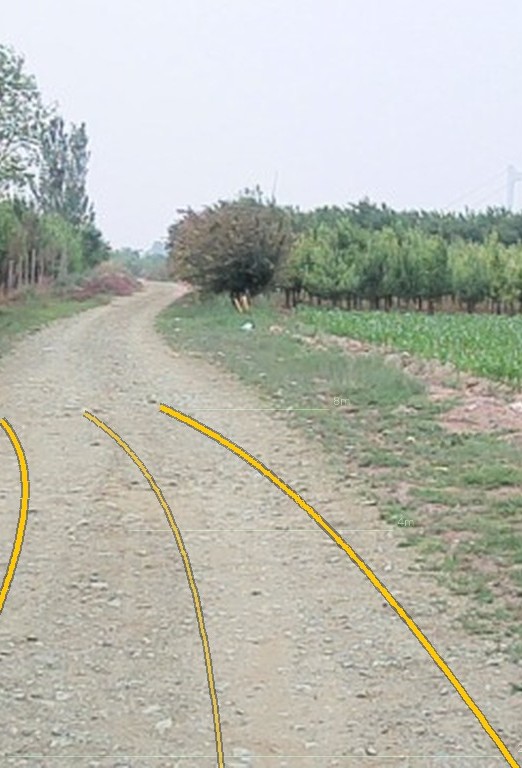
The rover driving the planned path

Drives it, and holds if the link drops.

DRIVE
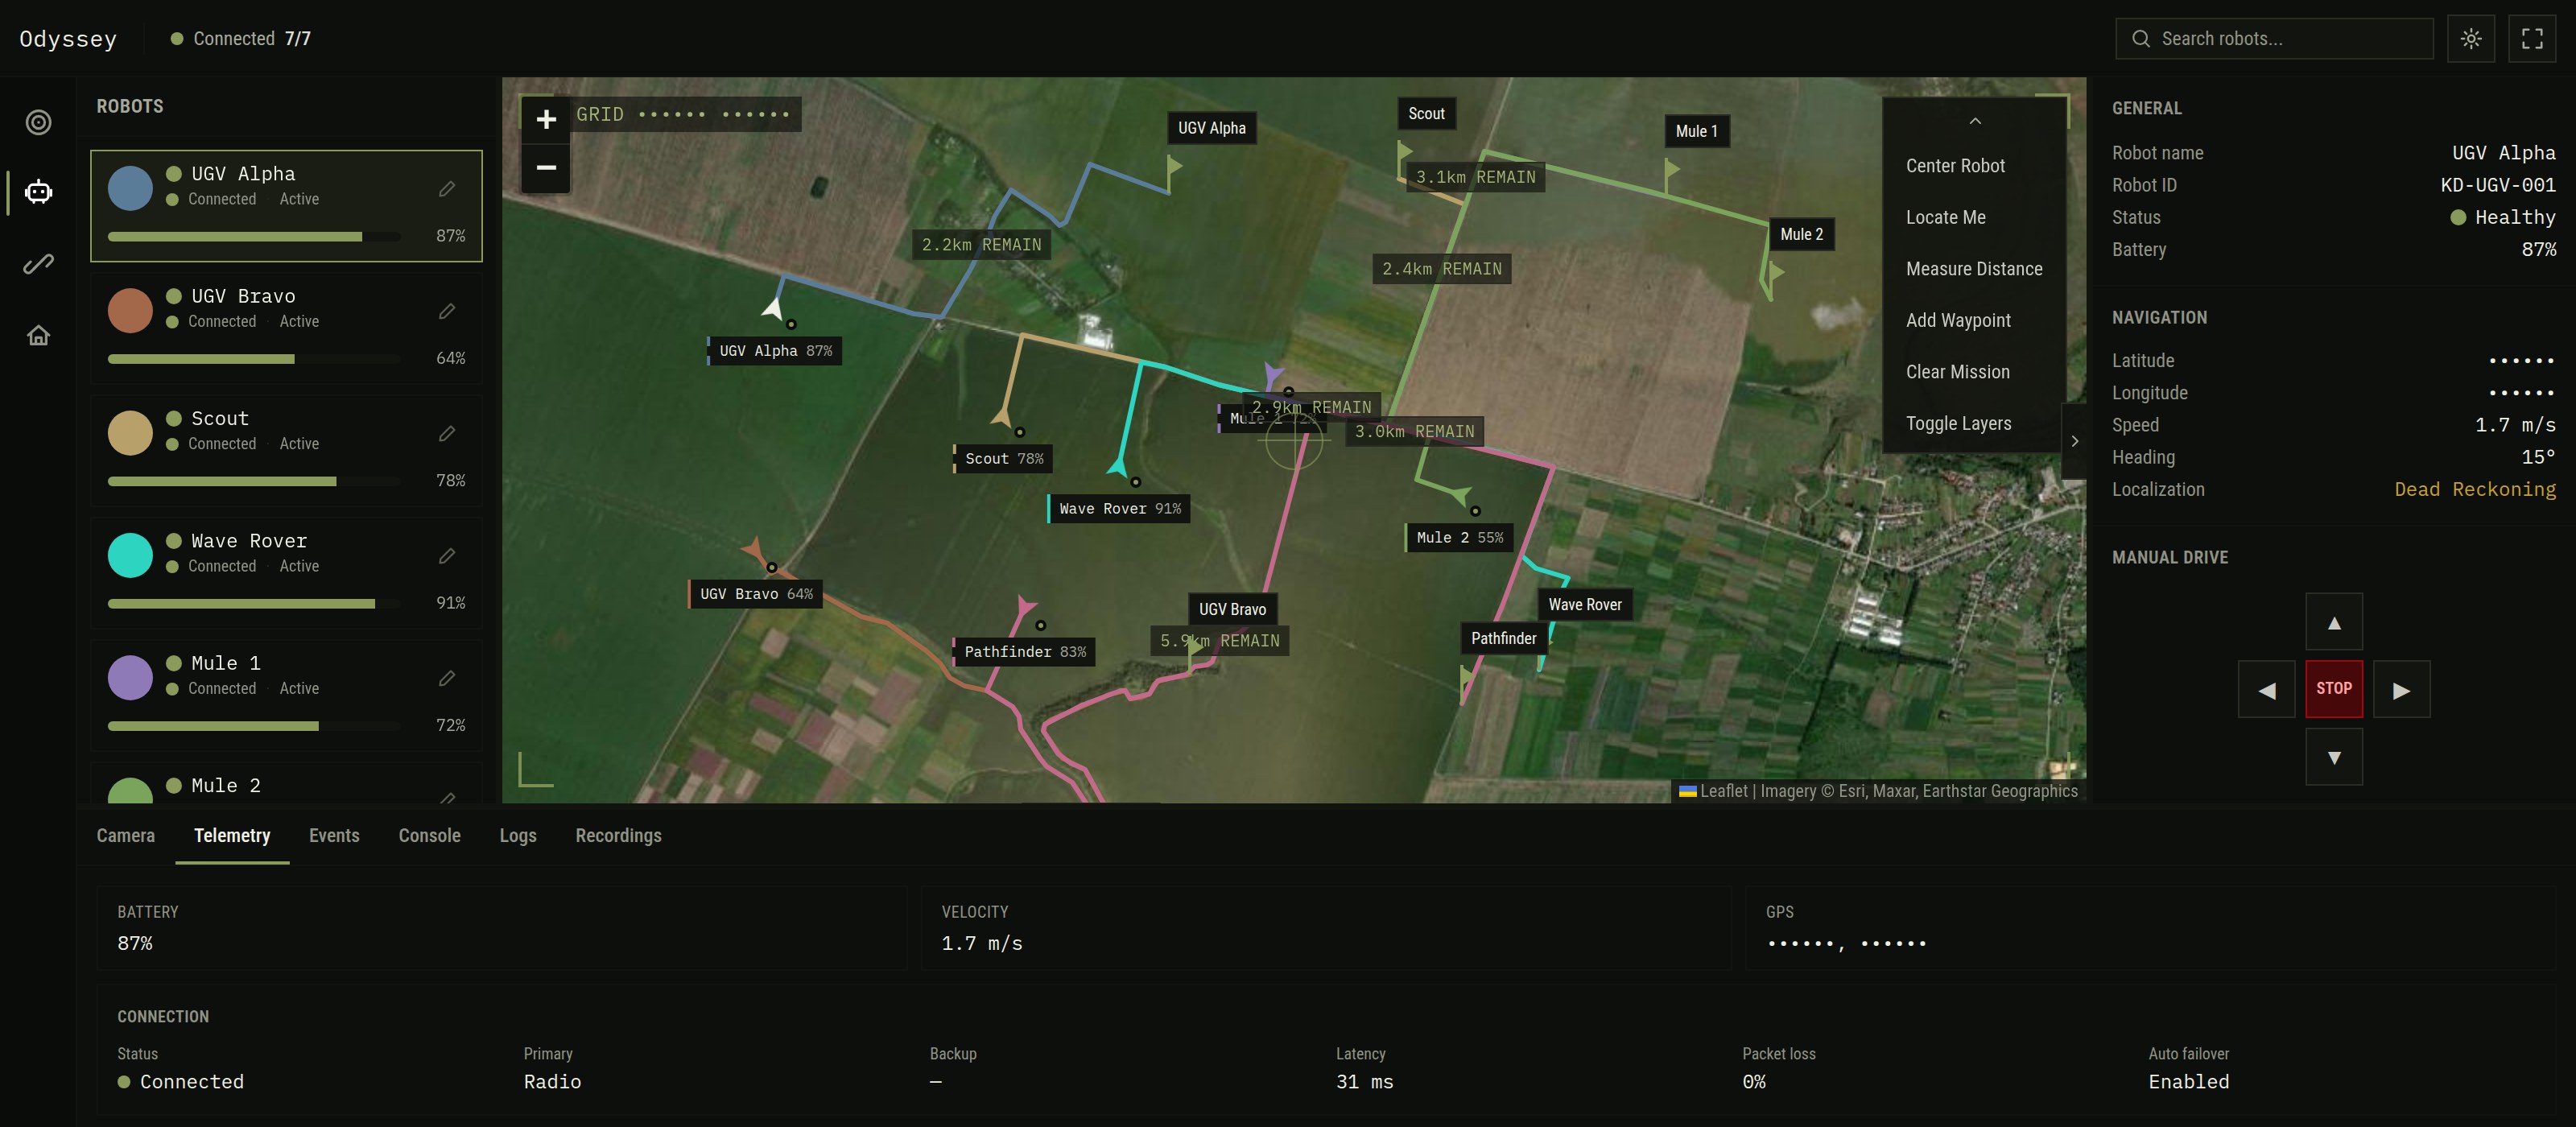
One operator

> The whole fleet on one screen.

The Odyssey app: seven robots on missions kilometres apart, each on a route the app planned along real tracks
┤WORK WITH US├

> Put Odyssey on your robots.

> contact@kyivdynamics.com